Current issue
Online first
Archive
About the Journal
Aims and scope
Publisher and Editorial
Advertising policy
Repository policy
Contact
Copyright
For Authors
Paper review procedures
Procedures protecting authentic authorship of papers
Paper preparation manual
Plagiarism check
Publication ethics
Reviewers
APC
Open Access Policy
Editorial and Scientific Board
Contact
Reviewers
Risk assessment and safety strategies for industrial robots use in transport
1
Faculty of Mechanical Engineering, Lublin University of Technology, Poland
2
Faculty of Mechanical Engineering, Bydgoszcz University of Science and Technology, Poland
These authors had equal contribution to this work
Submission date: 2025-11-30
Final revision date: 2026-04-21
Acceptance date: 2026-04-27
Online publication date: 2026-09-25
Corresponding author
KEYWORDS
TOPICS
ABSTRACT
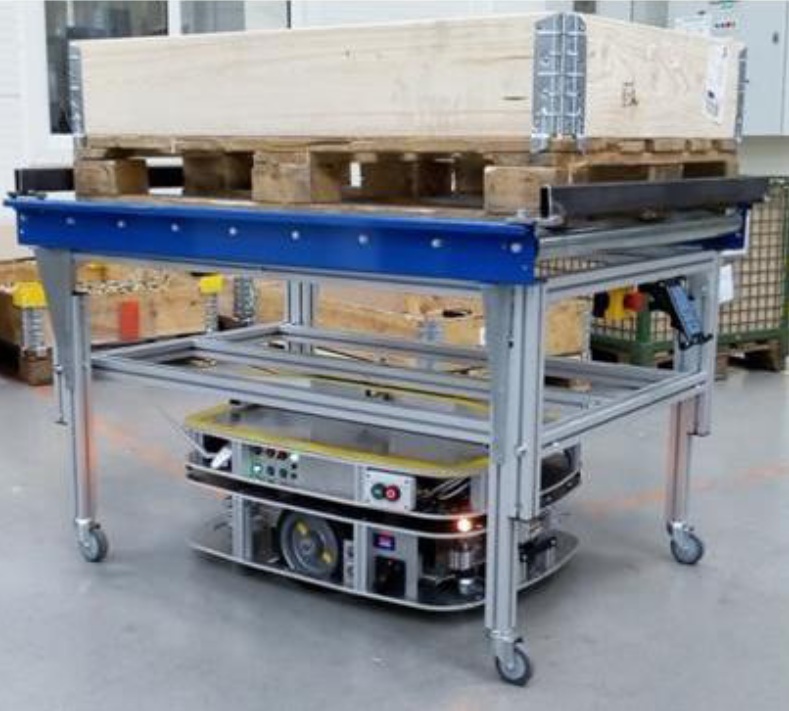
The development of robotic logistics processes is placing increasing emphasis on the operational safety of industrial robots in goods transport. Mobile robots, such as AGVs (Automated Guided Vehicles) and AMRs (Autonomous Mobile Robots), play a significant role in streamlining internal transport, but their integration with internal infrastructure carries the risk of collisions, breakdowns, and operational disruptions. This article presents the fundamental safety aspects of transport robots, with particular emphasis on applicable standards and technical systems based on sensors, LiDAR (Light Detection and Ranging), and vision systems. Selected industrial implementations are also discussed, demonstrating the need for a comprehensive approach to designing safety zones and traffic management in robotic warehouses. The aim of this paper is to highlight the importance of safety aspects in the context of the growing use of robots in logistics and internal transport and to identify directions for further development in this area.
REFERENCES (33)
1.
Alatise M, Hancke G. A review on challenges of autonomous mobile robot and sensor fusion methods. IEEE Access. 2020;8:39830-39846. https://doi.org/10.1109/ACCESS....
2.
Andrych-Zalewska M, Chłopek Z, Lasocki J, Merkisz J, Pielecha J. A stochastic approach to the analysis of pollutant emissions and fuel consumption of motor vehicles driven in real traffic. Appl Sci. 2024;14(23):11346. https://doi.org/10.3390/app142....
3.
Babuchowska P, Pielecha I. Camera systems – key technology for ADAS in autonomous vehicles. Combustion Engines. 2025;203(4):155-163. https://doi.org/10.19206/CE-20....
4.
Bechtsis D, Tsolakis N, Vlachos D, Iakovou E. Sustainable supply chain management in the digitalisation era: the impact of automated guided vehicles. J Clean Prod. 2017;142:3970-3984. https://doi.org/10.1016/j.jcle....
5.
Bostelman R, Hong T. Safety standard advancement toward mobile robot use near humans. Proc Int Conf Safety Industrial Automated Systems. 2005:1–8. https://tsapps.nist.gov/public....
6.
Bozhinoski D, Di Ruscio D, Malavolta I, Pelliccione P, Crnkovic I. Safety for mobile robotic system: A systematic mapping study from a software engineering perspective. J Syst Softw. 2019;151:150-179. https://doi.org/10.1016/j.jss.....
7.
Čižiūnienė K, Matijošius J, Sokolovskij E, Balevičiūtė J. Assessment of implementing green logistics principles in railway transport: the case of Lithuania. Sustainability. 2024;16:2716. https://doi.org/10.3390/su1607....
8.
Dąbrowska A, Giel R, Werbińska-Wojciechowska S. Human safety in autonomous transport systems – review and case study. J KONBiN. 2021;51:57-71. https://doi.org/10.2478/jok-20....
9.
Das S. Design and methodology of automated guided vehicle. IOSR J Mech Civ Eng. 2016;13(3):29-35.
10.
Grabowski Ł, Drozd A, Karabela M, Karpiuk W. Aerodynamic and rolling resistances of heavy duty vehicle. Simulation of energy consumption. Appl Comput Sci. 2024;20(3):116-131. https://doi.org/10.35784/acs-2....
11.
Halme RJ, Lanz M, Kämäräinen J, Pieters R, Latokartano J, Hietanen A. Review of vision-based safety systems for human-robot collaboration. Procedia CIRP. 2018;72:111-116. https://doi.org/10.1016/j.proc....
12.
Hentout A, Aouache M, Maoudj A, Akli I. Human–robot interaction in industrial collaborative robotics: A literature review of the decade 2008–2017. Adv Robot. 2019;33(15-16):764-799. https://doi.org/10.1080/016918....
13.
Hong S, Park D. ML-based fast and precise embedded rack detection software for docking and transport of autonomous mobile robots using 2-D LiDAR. IEEE Embed Syst Lett. 2024;16:401-404. https://doi.org/10.1109/LES.20....
14.
Kaczmarek W, Panasiuk J. Analiza procesów zrobotyzowanego sortowania, pakowania i paletyzacji. Napędy i Sterowanie. 2018;20(9):142-149.
15.
Kaczmarek W, Panasiuk J. Wykorzystanie robotów przemysłowych w wybranych aplikacjach (in Polish). Napędy i Sterowanie. 2019;21(2):48-55.
16.
Korbiel T, Czerwiński S, Kania J. Utrzymanie ruchu oraz eksploatacja maszyn w przemyśle 4.0 (in Polish). Systemy Wspomagania w Inżynierii Produkcji. 2023;12(1):137-151. https://doi.org/10.37190/SiWIP....
17.
Le-Anh T, De Koster MBM. A review of design and control of automated guided vehicle systems. Eur J Oper Res. 2006;171(1):1-23. https://doi.org/10.1016/j.ejor....
18.
Liu SB, Roehm H, Heinzemann C, Lütkebohle I, Oehlerking J, Althoff M. Provably safe motion of mobile robots in human environments. Proc IEEE/RSJ Int Conf Intell Robots Syst. 2017:1351-1357. https://doi.org/10.1109/IROS.2....
19.
Małopolski W, Skoczypiec S. The concept of an autonomous mobile robot for automating transport tasks in high-bay warehouses. Adv Sci Technol Res J. 2024;18:1-10. https://doi.org/10.12913/22998....
20.
Norton A, Gavriel P, Yanco H. A standard test method for evaluating navigation and obstacle avoidance capabilities of AGVs and AMRs. Smart Sustain Manuf Syst. 2019;3:20190028. https://doi.org/10.1520/SSMS20....
21.
Norton A, Yanco H. Preliminary development of a test method for obstacle detection and avoidance in industrial environments. In: Autonomous Industrial Vehicles: From the Laboratory to the Factory Floor. ASTM STP. 2016:23-40. https://doi.org/10.1520/STP159....
22.
Packianathan R, Arumugam G, Malaiarasan A, Natarajan SK. Integrating industrial robotics and Internet of Things (IoT) in Smart Transportation System. https://doi.org/10.1007/978-3-....
23.
Patel AR, Azadi S, Babaee MH, Mollaei N, Patel KL, Mehta DR. Significance of robotics in manufacturing, energy, goods and transport sector in IoT paradigm. 2018.
24.
Pratama PS, Jeong SK, Park SS, Kim SB. Moving object tracking and avoidance algorithm for differential driving AGV based on laser measurement technology. Int J Sci Eng. 2012;4(1):11-15. https://doi.org/10.12777/ijse.....
25.
Ramanathan KC, Mohan M, Arockia Dhanraj J. Backward motion planning and control of multiple mobile robots moving in tightly coupled formations. Appl Comput Sci. 2021;17(3):60-72. https://doi.org/10.35784/acs-2....
26.
Reithner I, Papa M, Aburaia M, Wöber W, Ambros C. Analysis of the interaction between safety and security demonstrated on a mobile robot and a production network. 2021. https://doi.org/10.2507/32nd.d....
27.
Ribeiro T, Garcia I, Pereira D, Ribeiro J, Lopes G, Ribeiro AF. Development of a prototype robot for transportation within industrial environments. Proc IEEE Int Conf Autonomous Robot Systems and Competitions. 2017:192-197. https://doi.org/10.1109/ICARSC....
28.
Stączek P, Pizoń J, Danilczuk W, Gola A. A digital twin approach for the improvement of an autonomous mobile robots (AMR’s) operating environment – a case study. Sensors. 2021;21(23):7830. https://doi.org/10.3390/s21237....
29.
Straszko J, Parus W, Paterkowski W. Kinetics of catalytic combustion processes of air admixtures. Arch Environ Prot. 2015;41. https://doi.org/10.1515/aep-20....
30.
Turpak S, Saukhanov N, Ostrohliad O, Taran I, Moroz D. Improving the efficiency of management of transport and energy resources of the logistics system of an industrial enterprise. Naukovyi Visnyk Natsionalnoho Hirnychoho Universytetu. 2024:143-150. https://doi.org/10.33271/nvngu....
31.
Vogel C, Walter C, Elkmann N. A projection-based sensor system for ensuring safety while grasping and transporting objects by an industrial robot. Proc IEEE/RSJ Int Conf Intell Robots Syst. 2013:5359-5364. https://doi.org/10.1109/IROS.2....
32.
Wróbel R, Sroka Z, Sierzputowski G, Dimitrov R, Mihaylov V, Ivanov D. Driving protocols: the possibility of using routing protocols in autonomous transport. Combustion Engines. 2024;196(1):3-9. https://doi.org/10.19206/CE-17....
33.
Zientek I, Maj D, Skrobol A, Motylski P. Wprowadzanie innowacji w zakresie automatyzacji transportu wewnętrznego w przedsiębiorstwach i zakładach produkcyjnych (in Polish). J TransLogistics. 2018;4(1):157-166.
Share
RELATED ARTICLE
| eISSN: | 2658-1442 |
| ISSN: | 2300-9896 |
The scientific journal is financed under the Agreement 185/WCN/2019/1 from the funds of the Minister of Science and Higher Education
© 2006-2026 Journal hosting platform by Bentus
We process personal data collected when visiting the website. The function of obtaining information about users and their behavior is carried out by voluntarily entered information in forms and saving cookies in end devices. Data, including cookies, are used to provide services, improve the user experience and to analyze the traffic in accordance with the Privacy policy. Data are also collected and processed by Google Analytics tool (more).
You can change cookies settings in your browser. Restricted use of cookies in the browser configuration may affect some functionalities of the website.
You can change cookies settings in your browser. Restricted use of cookies in the browser configuration may affect some functionalities of the website.